泊车场景
一、场景描述:
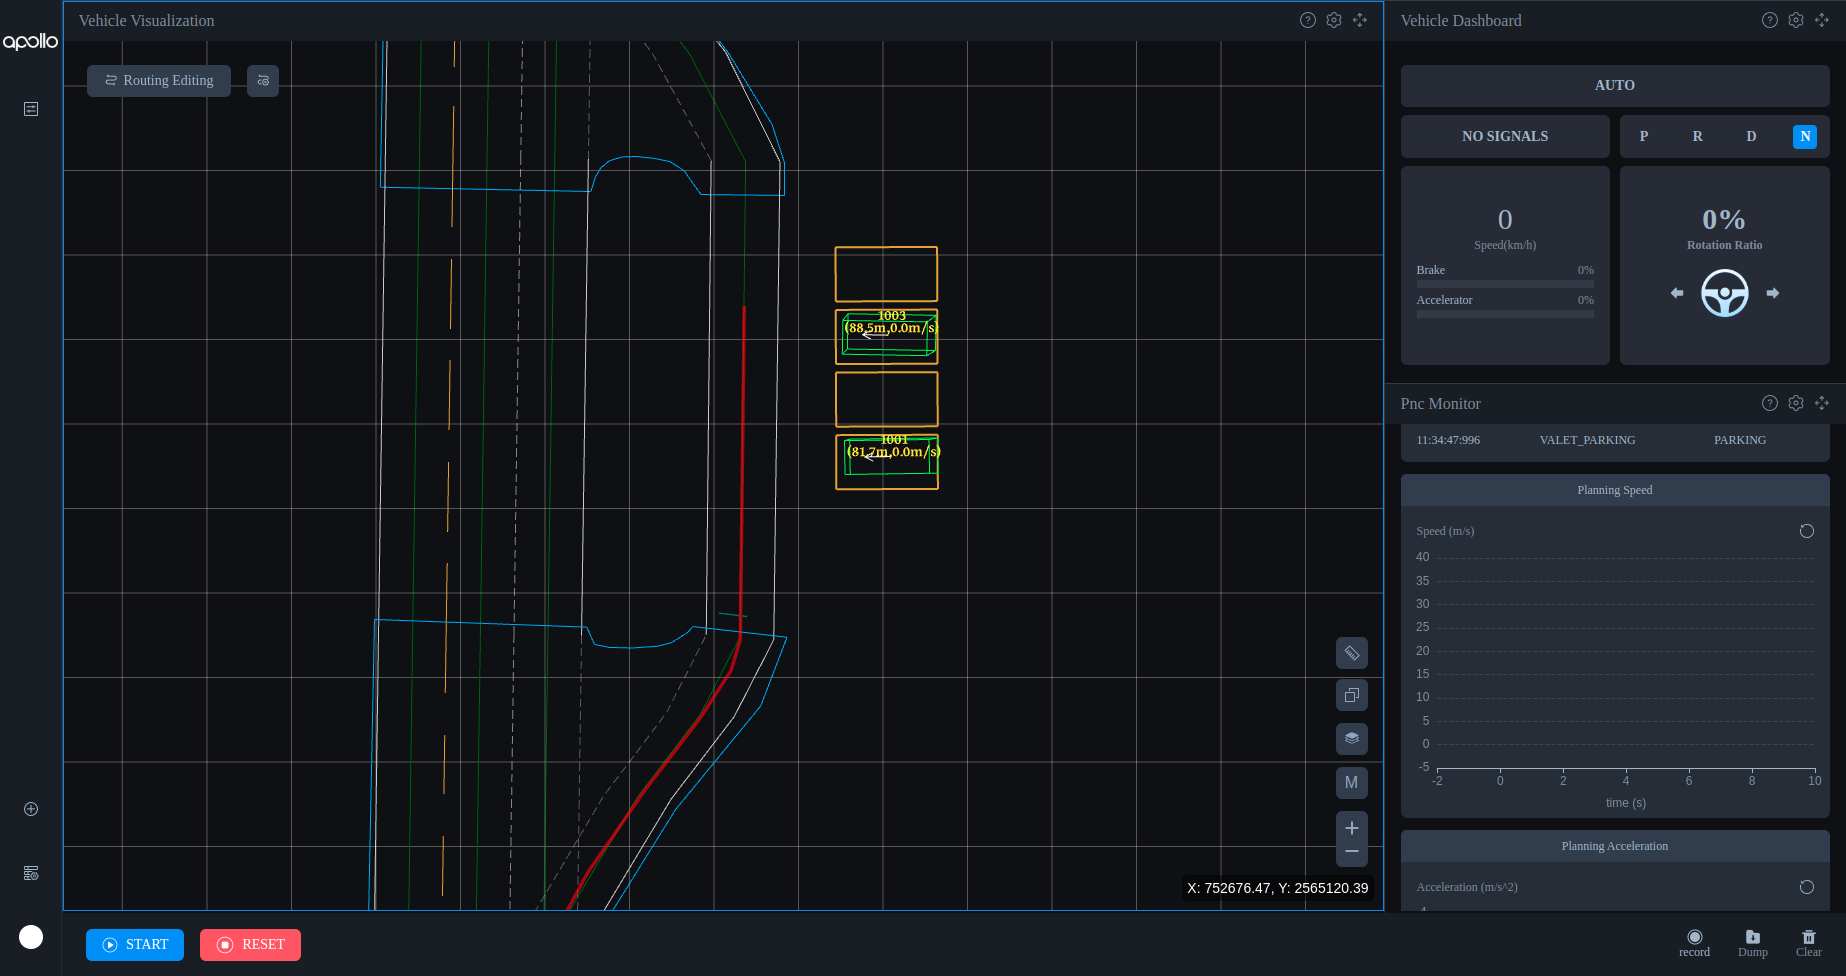
在主车进入停车场时,根据当前停车场的车位状况(有车位已被占用),搜索离自身最近的停车位。
场景图示:
二、实验流程
实验流程大纲
- 默认配置参数规划效果
- 启动dreamview并观察默认代码下车辆在泊车场景中的仿真效果。
- 泊车场景场景实践
- 添加planning scenario插件
- 修改相应代码
- 保存修改后的配置参数,并重新启动planning模块。
- 运行车辆规划模块,并在dreamview上观察车辆驶入泊车场景中的仿真效果。
三、实验步骤
默认配置参数规划效果
启动dreamview并观察默认代码下车辆通过施工区域的仿真效果。
(1)在终端中,执行DreamView启动指令,执行成功后,打开浏览器输入(http://localhost:8888/)进入dremview中。
aem bootstrap start --plus
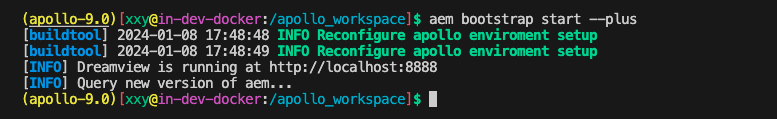
当出现如下,即表示dreamview启动成功了。
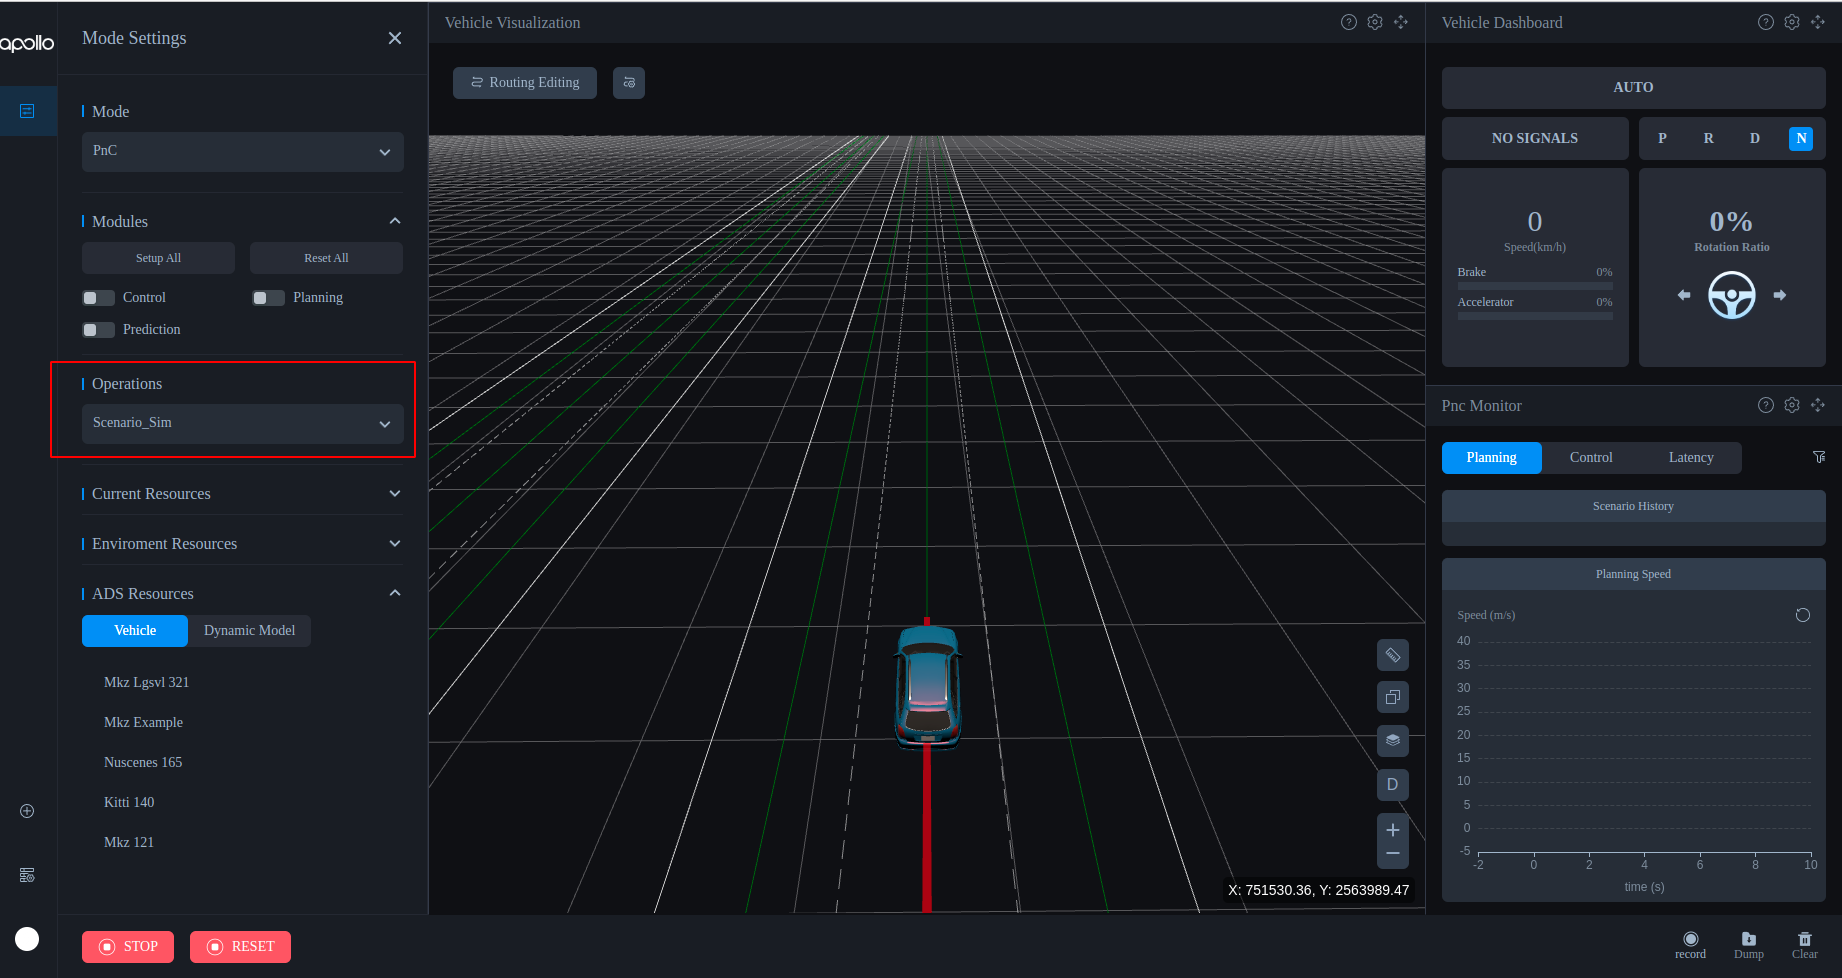
(2)左侧导航栏打开Mode Setting面板,模式选择PnC Mode,操作选择Scenario_sim,进入仿真模式。
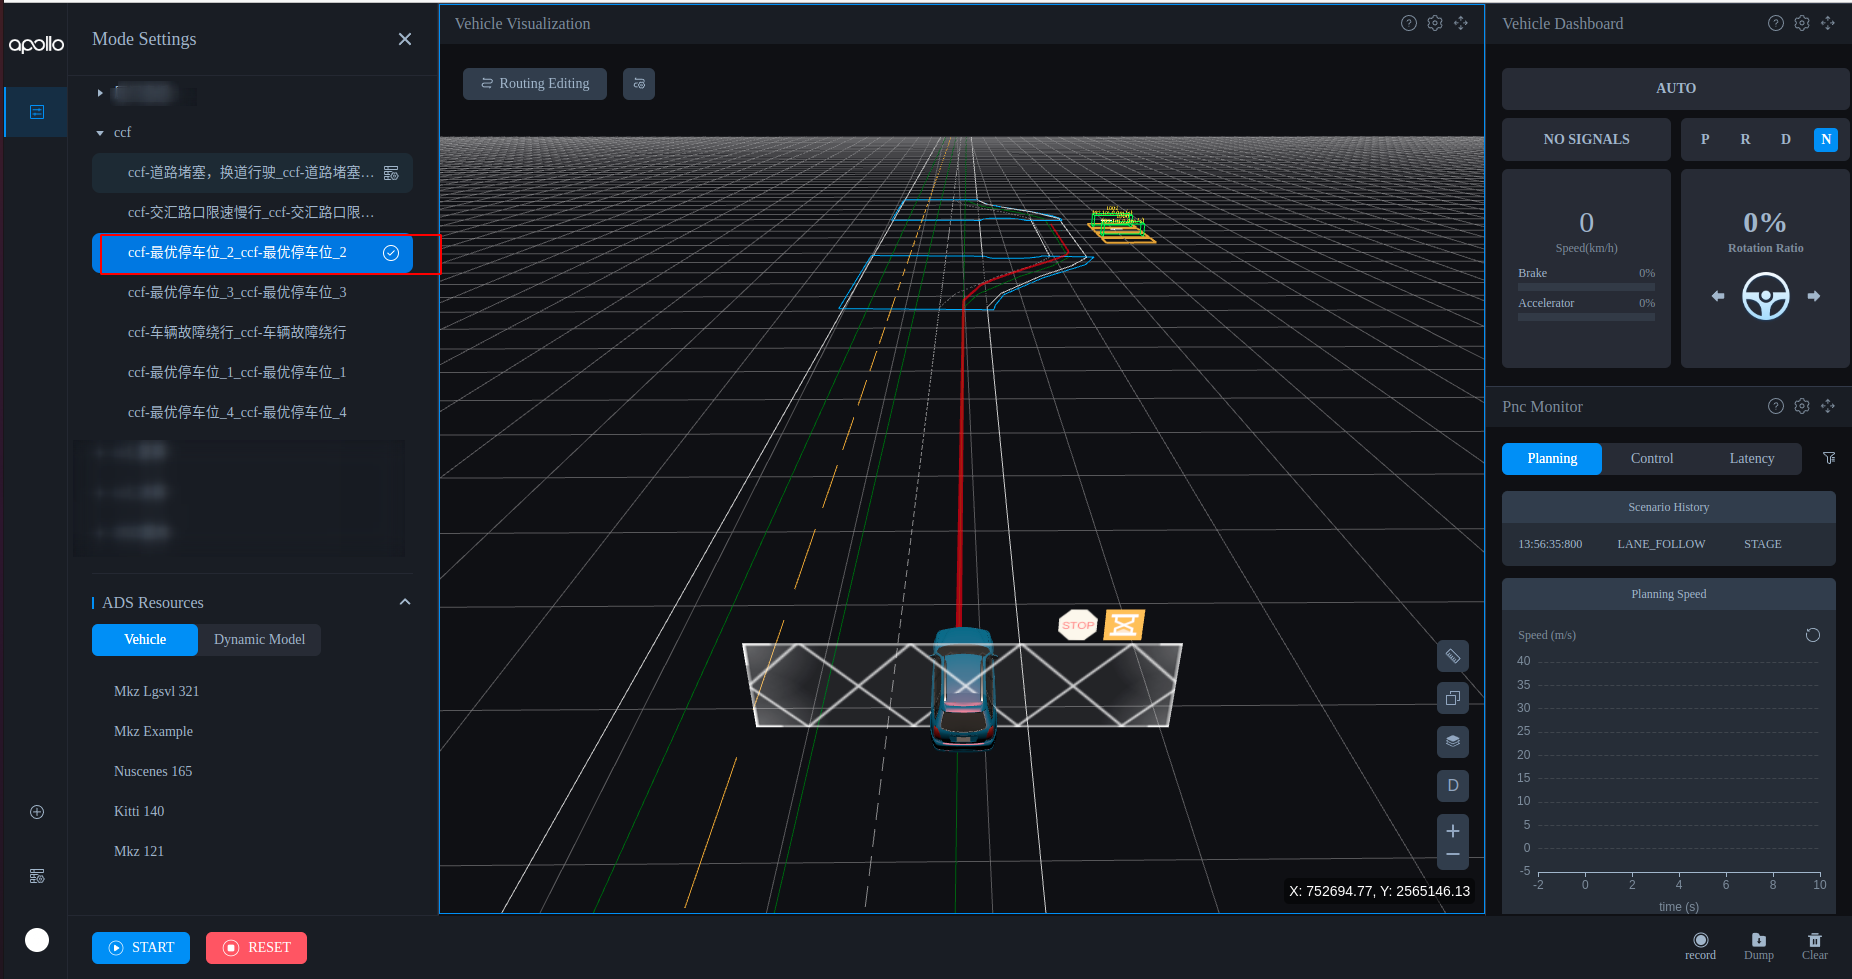
(3)选择相关场景(最优停车位_2)
(4)启动台planning 和 prediction模块,并点击start启动仿真
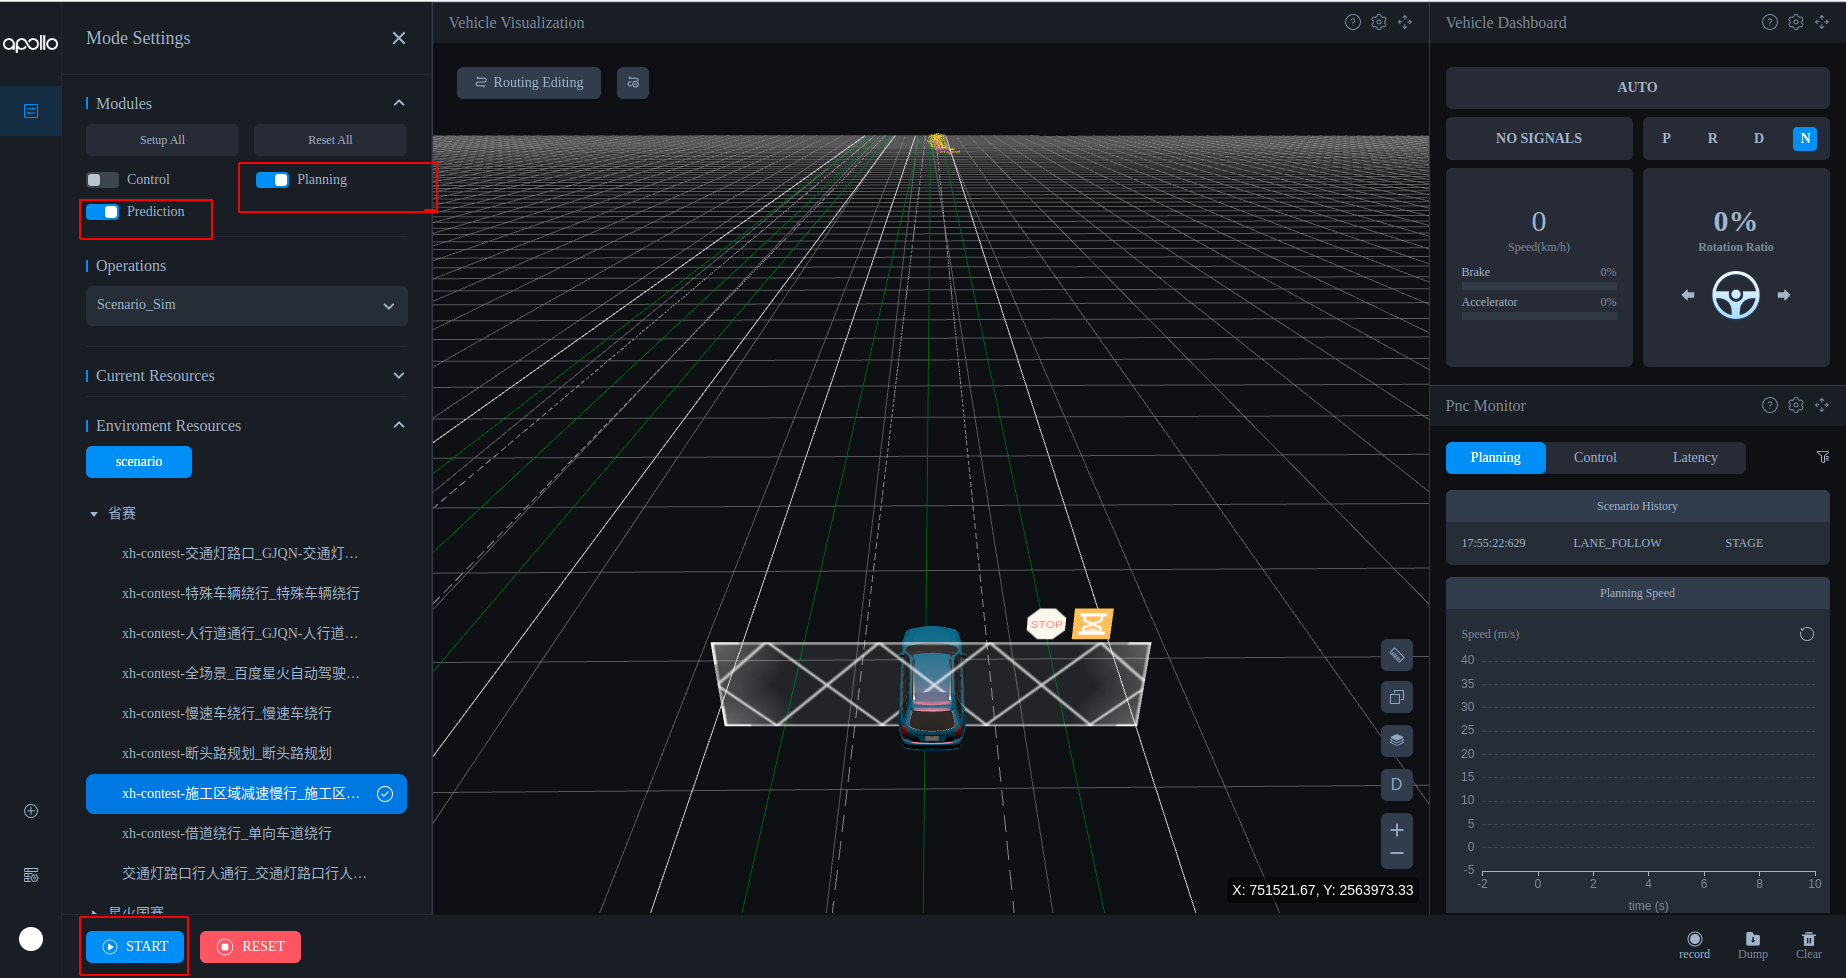
(5)观察
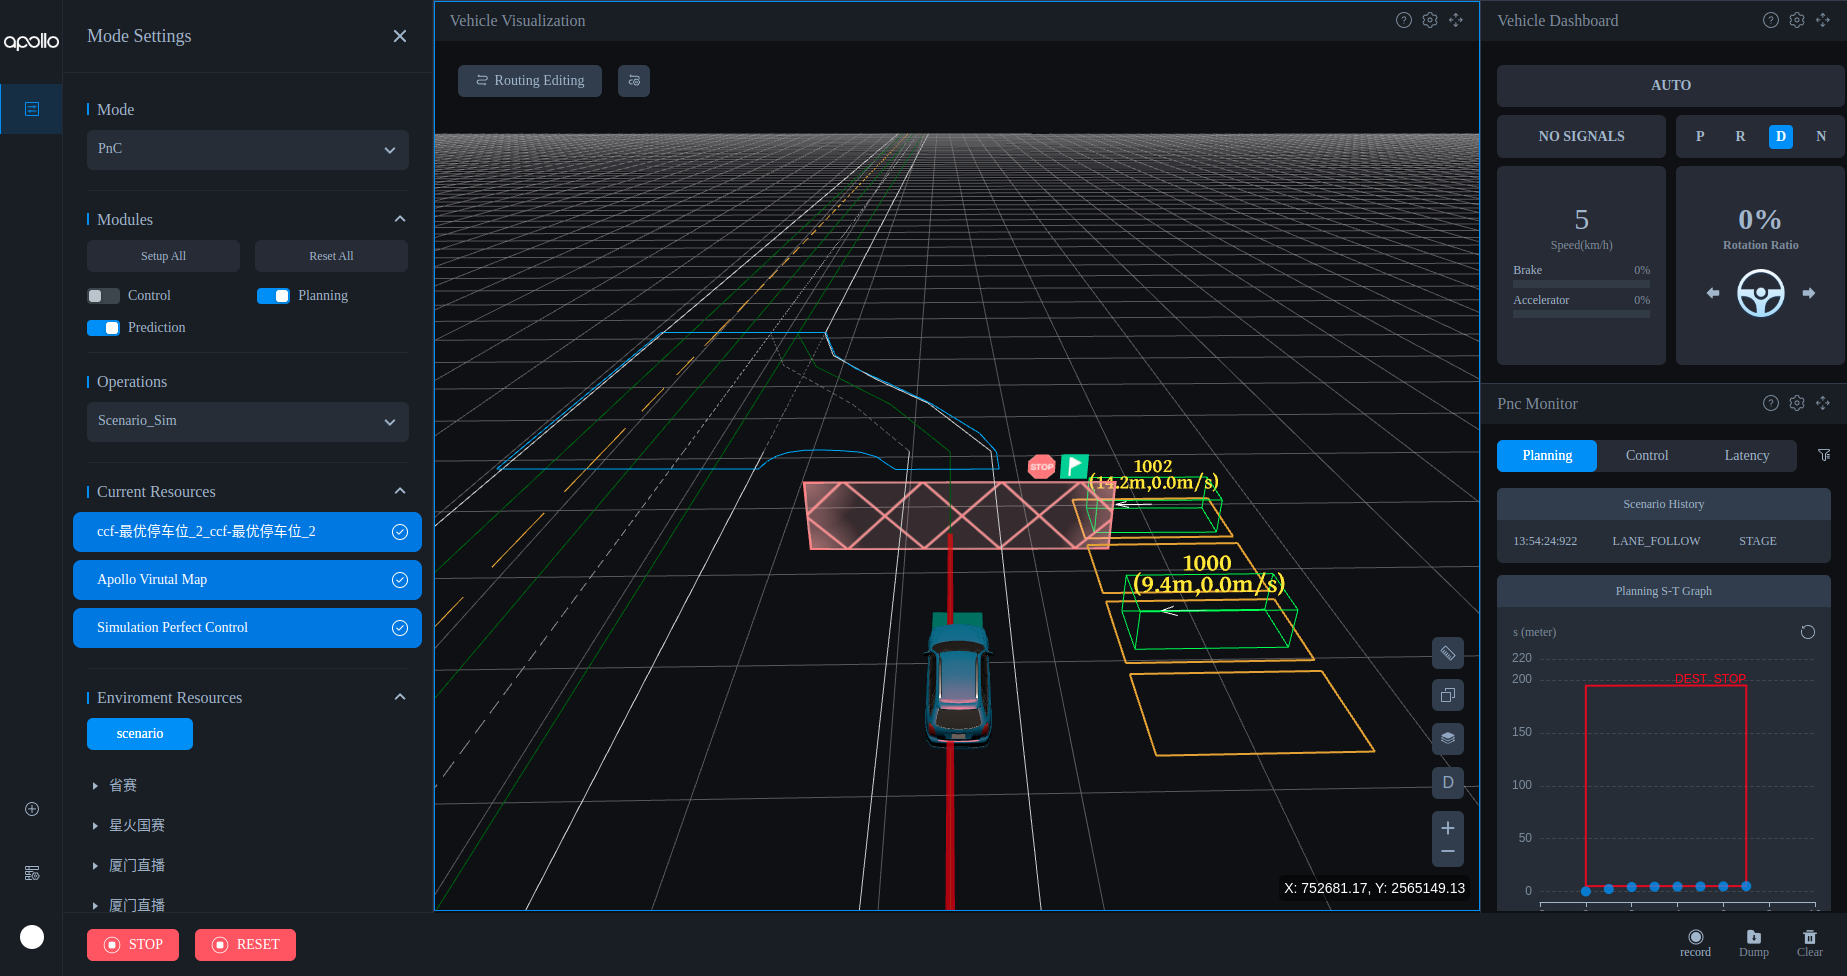
泊车场景场景实践
添加planning scenario插件
- 在包管理环境下创建插件模板,通过以下命令可以创建一个搜索停车位场景(BestParkingSpace)插件的模板
buildtool create --template plugin \--namespaces planning \--dependencies planning:binary:planning \--base_class_name apollo::planning::Scenario \--class_name BestParkingSpace \modules/planning/scenarios/best_parking_space
- 场景切入条件
planning command里存在泊车命令
距离泊车点距离parking_spot_range_to_start以内
- 阶段
阶段名 | 类型 | 描述 |
|
| 引导车辆沿主路行驶到泊车位 |
|
| 泊入车位 |
- 配置
文件路径 | 类型/结构 | 说明 |
|
| 场景的配置文件 |
|
| 场景的流水线文件 |
修改相应代码
- 相应文件夹结构
tree modules/planning/scenarios/best_parking_space/
modules/planning/scenarios/best_parking_space/├── BUILD├── best_parking_space.cc├── best_parking_space.h├── conf│ ├── best_parking_approaching_parking_spot│ │ └── open_space_pre_stop_decider.pb.txt│ ├── best_parking_parking│ │ ├── open_space_roi_decider.pb.txt│ │ ├── open_space_trajectory_partition.pb.txt│ │ └── open_space_trajectory_provider.pb.txt│ ├── pipeline.pb.txt│ └── scenario_conf.pb.txt├── cyberfile.xml├── plugins.xml├── proto│ ├── BUILD│ └── best_parking_space.proto├── stage_approaching_parking_spot.cc├── stage_approaching_parking_spot.h├── stage_parking.cc└── stage_parking.h
- 添加best_parking_space场景代码
modules/planning/scenarios/best_parking_space/best_parking_space.cc
/******************************************************************************* @file best_parking_space.cc*****************************************************************************/#include "modules/planning/scenarios/best_parking_space/best_parking_space.h"#include "modules/planning/planning_base/common/frame.h"// #include "modules/planning/scenarios/best_parking_space/stage_approaching_parking_spot.h"// #include "modules/planning/scenarios/best_parking_space/stage_parking.h"namespace apollo {namespace planning {using apollo::common::VehicleState;using apollo::common::math::Polygon2d;using apollo::common::math::Vec2d;using apollo::hdmap::ParkingSpaceInfoConstPtr;using apollo::hdmap::Path;using apollo::hdmap::PathOverlap;bool BestParkingSpaceScenario::Init(std::shared_ptr<DependencyInjector> injector, const std::string& name) {if (init_) {return true;}if (!Scenario::Init(injector, name)) {AERROR << "failed to init scenario" << Name();return false;}if (!Scenario::LoadConfig<BestParkingSpaceConfig>(&context_.scenario_config)) {AERROR << "fail to get config of scenario" << Name();return false;}hdmap_ = hdmap::HDMapUtil::BaseMapPtr();CHECK_NOTNULL(hdmap_);init_ = true;return true;}bool BestParkingSpaceScenario::IsTransferable(const Scenario* const other_scenario, const Frame& frame) {std::string target_parking_spot_id;double parking_spot_range_to_start = context_.scenario_config.parking_spot_range_to_start();auto parking_command = frame.local_view().planning_command->has_parking_command();auto parking_spot_id = frame.local_view().planning_command->parking_command().has_parking_spot_id();if (other_scenario == nullptr || frame.reference_line_info().empty()) {return false;if (parking_command && parking_spot_id) {target_parking_spot_id = frame.local_view().planning_command->parking_command().parking_spot_id();}}if (!parking_command) {const auto routing_end = frame.local_view().end_lane_way_point;common::PointENU end_postion;end_postion.set_x(routing_end->pose().x());end_postion.set_y(routing_end->pose().y());if (nullptr == routing_end) {return false;}common::SLPoint dest_sl;const auto& reference_line_info = frame.reference_line_info().front();const auto& reference_line = reference_line_info.reference_line();reference_line.XYToSL(routing_end->pose(), &dest_sl);const double adc_front_edge_s = reference_line_info.AdcSlBoundary().end_s();const double adc_distance_to_dest = dest_sl.s() - adc_front_edge_s;if (adc_distance_to_dest > parking_spot_range_to_start) {return false;}if (target_parking_spot_id.empty()) {std::vector<apollo::hdmap::ParkingSpaceInfoConstPtr> parking_spaces;if (hdmap_->GetParkingSpaces(end_postion, parking_spot_range_to_start, &parking_spaces) == 0&& parking_spaces.size() > 0) {for (auto parking_space : parking_spaces) {target_parking_spot_id = parking_space->parking_space().id().id();}}}}if (target_parking_spot_id.empty()) {return false;}AINFO << "target_parking_spot_id" << target_parking_spot_id;const auto& nearby_path = frame.reference_line_info().front().reference_line().map_path();PathOverlap parking_space_overlap;const auto& vehicle_state = frame.vehicle_state();if (!SearchTargetParkingSpotOnPath(nearby_path, target_parking_spot_id, &parking_space_overlap)) {ADEBUG << "No such parking spot found after searching all path forward ""possible"<< target_parking_spot_id;return false;}if (!CheckDistanceToParkingSpot(frame, vehicle_state, nearby_path, parking_spot_range_to_start, parking_space_overlap)) {ADEBUG << "target parking spot found, but too far, distance larger than ""pre-defined distance"<< target_parking_spot_id;return false;}context_.target_parking_spot_id = target_parking_spot_id;return true;}bool BestParkingSpaceScenario::SearchTargetParkingSpotOnPath(const Path& nearby_path,const std::string& target_parking_id,PathOverlap* parking_space_overlap) {const auto& parking_space_overlaps = nearby_path.parking_space_overlaps();for (const auto& parking_overlap : parking_space_overlaps) {if (parking_overlap.object_id == target_parking_id) {*parking_space_overlap = parking_overlap;return true;}}return false;}bool BestParkingSpaceScenario::CheckDistanceToParkingSpot(const Frame& frame,const VehicleState& vehicle_state,const Path& nearby_path,const double parking_start_range,const PathOverlap& parking_space_overlap) {// TODO(Jinyun) parking overlap s are wrong on map, not usableconst hdmap::HDMap* hdmap = hdmap::HDMapUtil::BaseMapPtr();hdmap::Id id;double center_point_s, center_point_l;id.set_id(parking_space_overlap.object_id);ParkingSpaceInfoConstPtr target_parking_spot_ptr = hdmap->GetParkingSpaceById(id);Vec2d left_bottom_point = target_parking_spot_ptr->polygon().points().at(0);Vec2d right_bottom_point = target_parking_spot_ptr->polygon().points().at(1);Vec2d right_top_point = target_parking_spot_ptr->polygon().points().at(2);Vec2d left_top_point = target_parking_spot_ptr->polygon().points().at(3);Vec2d center_point = (left_bottom_point + right_bottom_point + right_top_point + left_top_point) / 4.0;nearby_path.GetNearestPoint(center_point, ¢er_point_s, ¢er_point_l);double vehicle_point_s = 0.0;double vehicle_point_l = 0.0;Vec2d vehicle_vec(vehicle_state.x(), vehicle_state.y());nearby_path.GetNearestPoint(vehicle_vec, &vehicle_point_s, &vehicle_point_l);if (std::abs(center_point_s - vehicle_point_s) < parking_start_range) {return true;}return false;}} // namespace planning} // namespace apollo
添加best_parking_space头文件:
modules/planning/scenarios/best_parking_space/best_parking_space.h
/******************************************************************************* @file best_parking_space.h*****************************************************************************/#pragma once#include <memory>#include <string>#include "modules/common_msgs/map_msgs/map_id.pb.h"#include "modules/planning/scenarios/best_parking_space/proto/best_parking_space.pb.h"#include "cyber/plugin_manager/plugin_manager.h"#include "modules/map/hdmap/hdmap_util.h"#include "modules/map/pnc_map/path.h"#include "modules/planning/planning_interface_base/scenario_base/scenario.h"#include "gtest/gtest.h"#include "cyber/common/file.h"#include "cyber/common/log.h"#include "modules/planning/planning_base/gflags/planning_gflags.h"namespace apollo {namespace planning {struct BestParkingSpaceContext : public ScenarioContext {BestParkingSpaceConfig scenario_config;std::string target_parking_spot_id;bool pre_stop_rightaway_flag = false;hdmap::MapPathPoint pre_stop_rightaway_point;};class BestParkingSpaceScenario : public Scenario {public:bool Init(std::shared_ptr<DependencyInjector> injector, const std::string& name) override;/*** @brief Get the scenario context.*/BestParkingSpaceContext* GetContext() override {return &context_;}bool IsTransferable(const Scenario* const other_scenario, const Frame& frame) override;private:static bool SearchTargetParkingSpotOnPath(const hdmap::Path& nearby_path,const std::string& target_parking_id,hdmap::PathOverlap* parking_space_overlap);static bool CheckDistanceToParkingSpot(const Frame& frame,const common::VehicleState& vehicle_state,const hdmap::Path& nearby_path,const double parking_start_range,const hdmap::PathOverlap& parking_space_overlap);private:bool init_ = false;BestParkingSpaceContext context_;const hdmap::HDMap* hdmap_ = nullptr;};CYBER_PLUGIN_MANAGER_REGISTER_PLUGIN(apollo::planning::BestParkingSpaceScenario, Scenario)} // namespace planning} // namespace apollo
- 开发best_parking_space场景的第一个阶段《靠近泊车位阶段》
modules/planning/scenarios/best_parking_space/stage_approaching_parking_spot.cc
#include <string>#include "modules/common/configs/vehicle_config_helper.h"#include "modules/common/vehicle_state/vehicle_state_provider.h"#include "modules/planning/scenarios/best_parking_space/stage_approaching_parking_spot.h"namespace apollo {namespace planning {bool StageBestApproachingParkingSpot::Init(const StagePipeline& config,const std::shared_ptr<DependencyInjector>& injector,const std::string& config_dir,void* context) {if (!Stage::Init(config, injector, config_dir, context)) {return false;}scenario_config_.CopyFrom(GetContextAs<BestParkingSpaceContext>()->scenario_config);return true;}StageResult StageBestApproachingParkingSpot::Process(const common::TrajectoryPoint& planning_init_point, Frame* frame) {ADEBUG << "stage: StageBestApproachingParkingSpot";CHECK_NOTNULL(frame);StageResult result;auto scenario_context = GetContextAs<BestParkingSpaceContext>();if (scenario_context->target_parking_spot_id.empty()) {return result.SetStageStatus(StageStatusType::ERROR);}*(frame->mutable_open_space_info()->mutable_target_parking_spot_id()) = scenario_context->target_parking_spot_id;frame->mutable_open_space_info()->set_pre_stop_rightaway_flag(scenario_context->pre_stop_rightaway_flag);*(frame->mutable_open_space_info()->mutable_pre_stop_rightaway_point())= scenario_context->pre_stop_rightaway_point;auto* reference_lines = frame->mutable_reference_line_info();for (auto& reference_line : *reference_lines) {auto* path_decision = reference_line.path_decision();if (nullptr == path_decision) {continue;}auto* dest_obstacle = path_decision->Find(FLAGS_destination_obstacle_id);if (nullptr == dest_obstacle) {continue;}ObjectDecisionType decision;decision.mutable_ignore();dest_obstacle->EraseDecision();dest_obstacle->AddLongitudinalDecision("ignore-dest-in-valet-parking", decision);}result = ExecuteTaskOnReferenceLine(planning_init_point, frame);scenario_context->pre_stop_rightaway_flag = frame->open_space_info().pre_stop_rightaway_flag();scenario_context->pre_stop_rightaway_point = frame->open_space_info().pre_stop_rightaway_point();if (CheckADCStop(*frame)) {next_stage_ = "BEST_PARKING_PARKING";return StageResult(StageStatusType::FINISHED);}if (result.HasError()) {AERROR << "StopSignUnprotectedStagePreStop planning error";return result.SetStageStatus(StageStatusType::ERROR);}return result.SetStageStatus(StageStatusType::RUNNING);}bool StageBestApproachingParkingSpot::CheckADCStop(const Frame& frame) {const auto& reference_line_info = frame.reference_line_info().front();const double adc_speed = injector_->vehicle_state()->linear_velocity();const double max_adc_stop_speed= common::VehicleConfigHelper::Instance()->GetConfig().vehicle_param().max_abs_speed_when_stopped();if (adc_speed > max_adc_stop_speed) {ADEBUG << "ADC not stopped: speed[" << adc_speed << "]";return false;}// check stop close enough to stop line of the stop_signconst double adc_front_edge_s = reference_line_info.AdcSlBoundary().end_s();const double stop_fence_start_s = frame.open_space_info().open_space_pre_stop_fence_s();const double distance_stop_line_to_adc_front_edge = stop_fence_start_s - adc_front_edge_s;if (distance_stop_line_to_adc_front_edge > scenario_config_.max_valid_stop_distance()) {ADEBUG << "not a valid stop. too far from stop line.";return false;}return true;}} // namespace planning} // namespace apollo
添加靠近停车位阶段头文件:
modules/planning/scenarios/best_parking_space/stage_approaching_parking_spot.h
#pragma once#include <memory>#include <string>#include "cyber/plugin_manager/plugin_manager.h"#include "modules/planning/planning_interface_base/scenario_base/stage.h"#include "modules/planning/scenarios/best_parking_space/best_parking_space.h"#include "gtest/gtest.h"#include "cyber/common/file.h"#include "cyber/common/log.h"#include "modules/planning/planning_base/gflags/planning_gflags.h"namespace apollo {namespace planning {class StageBestApproachingParkingSpot : public Stage {public:bool Init(const StagePipeline& config,const std::shared_ptr<DependencyInjector>& injector,const std::string& config_dir,void* context);StageResult Process(const common::TrajectoryPoint& planning_init_point, Frame* frame) override;private:bool CheckADCStop(const Frame& frame);BestParkingSpaceConfig scenario_config_;};CYBER_PLUGIN_MANAGER_REGISTER_PLUGIN(apollo::planning::StageBestApproachingParkingSpot, Stage)} // namespace planning} // namespace apollo
- 开发best_parking_space场景的第二个阶段《泊车阶段》
modules/planning/scenarios/best_parking_space/stage_parking.cc
#include "modules/planning/scenarios/best_parking_space/stage_parking.h"#include "modules/planning/planning_base/common/frame.h"namespace apollo {namespace planning {StageResult StageBestParking::Process(const common::TrajectoryPoint& planning_init_point, Frame* frame) {AERROR << "1";// Open space planning doesn't use planning_init_point from upstream because// of different stitching strategyauto scenario_context = GetContextAs<BestParkingSpaceContext>();frame->mutable_open_space_info()->set_is_on_open_space_trajectory(true);*(frame->mutable_open_space_info()->mutable_target_parking_spot_id()) = scenario_context->target_parking_spot_id;StageResult result = ExecuteTaskOnOpenSpace(frame);if (result.HasError()) {AERROR << "StageParking planning error";return result.SetStageStatus(StageStatusType::ERROR);}return result.SetStageStatus(StageStatusType::RUNNING);}StageResult StageBestParking::FinishStage() {return StageResult(StageStatusType::FINISHED);}} // namespace planning} // namespace apollo
添加泊车阶段头文件:
modules/planning/scenarios/best_parking_space/stage_parking.h
#pragma once#include <memory>#include "cyber/plugin_manager/plugin_manager.h"#include "modules/planning/planning_interface_base/scenario_base/stage.h"#include "modules/planning/scenarios/best_parking_space/best_parking_space.h"namespace apollo {namespace planning {class StageBestParking : public Stage {public:StageResult Process(const common::TrajectoryPoint& planning_init_point, Frame* frame) override;private:StageResult FinishStage();BestParkingSpaceConfig scenario_config_;};CYBER_PLUGIN_MANAGER_REGISTER_PLUGIN(apollo::planning::StageBestParking, Stage)} // namespace planning} // namespace apollo
- 完成场景的流水线配置conf/pipeline.pb.txt,配置需要启动的阶段,和每个阶段用到的任务
文件路径: modules/planning/scenarios/best_parking_space/conf/pipeline.pb.txt
stage: {name: "BEST_PARKING_APPROACHING_PARKING_SPOT"type: "StageBestApproachingParkingSpot"enabled: truetask {name: "OPEN_SPACE_PRE_STOP_DECIDER"type: "OpenSpacePreStopDecider"}task {name: "LANE_FOLLOW_PATH"type: "LaneFollowPath"}task {name: "LANE_BORROW_PATH"type: "LaneBorrowPath"}task {name: "FALLBACK_PATH"type: "FallbackPath"}task {name: "PATH_DECIDER"type: "PathDecider"}task {name: "RULE_BASED_STOP_DECIDER"type: "RuleBasedStopDecider"}task {name: "SPEED_BOUNDS_PRIORI_DECIDER"type: "SpeedBoundsDecider"}task {name: "SPEED_HEURISTIC_OPTIMIZER"type: "PathTimeHeuristicOptimizer"}task {name: "SPEED_DECIDER"type: "SpeedDecider"}task {name: "SPEED_BOUNDS_FINAL_DECIDER"type: "SpeedBoundsDecider"}task {name: "PIECEWISE_JERK_SPEED"type: "PiecewiseJerkSpeedOptimizer"}}stage: {name: "BEST_PARKING_PARKING"type: "StageBestParking"enabled: truetask {name: "OPEN_SPACE_ROI_DECIDER"type: "OpenSpaceRoiDecider"}task {name: "OPEN_SPACE_TRAJECTORY_PROVIDER"type: "OpenSpaceTrajectoryProvider"}task {name: "OPEN_SPACE_TRAJECTORY_PARTITION"type: "OpenSpaceTrajectoryPartition"}task {name: "OPEN_SPACE_FALLBACK_DECIDER"type: "OpenSpaceFallbackDecider"}}
- 添加场景的参数文件
- 将场景用到的参数配置到一个proto文件
文件路径:modules/planning/scenarios/best_parking_space/proto/best_parking_space.proto
syntax = "proto2";package apollo.planning;message BestParkingSpaceConfig {// Only when the distance between the vehicle and parking spot is smaller// than this value, "ValetParkingScenario" can be enteredoptional double parking_spot_range_to_start = 1 [default = 20.0];// Only when the distance between the vehicle and pre-stop distance is smaller// than this value, "StageApproachingParkingSpot" can be finishedoptional double max_valid_stop_distance = 2 [default = 1.0]; // meter}
- 将场景的参数配置添加到modules/planning/scenarios/best_parking_space/conf/scenario_conf.pb.txt中
parking_spot_range_to_start: 20.0max_valid_stop_distance: 1.0
- 将添加的scenario和stage插件注册到文件中modules/planning/scenarios/best_parking_space/plugins.xml
<library path="modules/planning/scenarios/best_parking_space/libbest_parking_space.so"><class type="apollo::planning::BestParkingSpaceScenario" base_class="apollo::planning::Scenario"></class><class type="apollo::planning::StageBestApproachingParkingSpot" base_class="apollo::planning::Stage"></class><class type="apollo::planning::StageBestParking" base_class="apollo::planning::Stage"></class></library>
- 将搜索停车位场景加入到planning的场景管理流水线中
输入指令同步配置参数
buildtool profile config init --package planning --profile=default && aem profile use default
文件路径:
profiles/current/modules/planning/planning_component/conf/public_road_planner_config.pb.txt
scenario {name: "EMERGENCY_PULL_OVER"type: "EmergencyPullOverScenario"}scenario {name: "EMERGENCY_STOP"type: "EmergencyStopScenario"}scenario {name: "BEST_PARKING"type: "BestParkingSpaceScenario"}scenario {name: "VALET_PARKING"type: "ValetParkingScenario"}scenario {name: "BARE_INTERSECTION_UNPROTECTED"type: "BareIntersectionUnprotectedScenario"}scenario {name: "STOP_SIGN_UNPROTECTED"type: "StopSignUnprotectedScenario"}scenario {name: "YIELD_SIGN"type: "YieldSignScenario"}scenario {name: "TRAFFIC_LIGHT_UNPROTECTED_LEFT_TURN"type: "TrafficLightUnprotectedLeftTurnScenario"}scenario {name: "TRAFFIC_LIGHT_UNPROTECTED_RIGHT_TURN"type: "TrafficLightUnprotectedRightTurnScenario"}scenario {name: "TRAFFIC_LIGHT_PROTECTED"type: "TrafficLightProtectedScenario"}scenario {name: "PULL_OVER"type: "PullOverScenario"}scenario {name: "PARK_AND_GO"type: "ParkAndGoScenario"}scenario {name: "LANE_FOLLOW"type: "LaneFollowScenario"}
- 修改BUILD文件,配置编译依赖。
将包内所有代码编译为一个apollo的插件,添加代码中所有对基础库的依赖
modules/planning/scenarios/best_parking_space/BUILD
load("//tools:apollo.bzl", "cyber_plugin_description")load("//tools:apollo_package.bzl", "apollo_cc_test", "apollo_package", "apollo_plugin")load("//tools:cpplint.bzl", "cpplint")package(default_visibility = ["//visibility:public"])filegroup(name = "best_parking_space_files",srcs = glob(["conf/**",]),)apollo_plugin(name = "libbest_parking_space.so",srcs = ["stage_approaching_parking_spot.cc","stage_parking.cc","best_parking_space.cc",],hdrs = ["stage_approaching_parking_spot.h","stage_parking.h","best_parking_space.h",],copts = ["-DMODULE_NAME=\\\"planning\\\""],description = ":plugins.xml",deps = ["//cyber","//modules/common_msgs/planning_msgs:planning_cc_proto","//modules/planning/planning_interface_base:apollo_planning_planning_interface_base","//modules/planning/scenarios/best_parking_space/proto:best_parking_space_proto",],)apollo_package()cpplint()
保存修改后的配置参数,并重新启动planning模块。
文件路径:modules/planning/scenarios/best_parking_space/
modules/planning/scenarios/best_parking_space/conf/best_parking_approaching_parking_spot/open_space_pre_stop_decider.pb.txt
stop_type: PARKING
文件路径:modules/planning/scenarios/best_parking_space/
conf/best_parking_parking/open_space_roi_decider.pb.txt | conf/best_parking_parking/open_space_trajectory_partition.pb.txt | conf/best_parking_parking/open_space_trajectory_provider.pb.txt |
|
|
|
编译代码: